Physical AI 前沿雷达 · 2026-09-20
每日自动更新的具身智能前沿雷达:八条主线、三语精炼、证据可查。
- 生成时间:
2026-09-20 01:51 UTC - 统计窗口:
2026-09-17 → 2026-09-20 (UTC) - 证据标注:O = 一手官方 · R = 论文/预印本 · M = 媒体或二手
今日重点
1. Robots Are Learning to Feel
- 主线: 数据引擎(采集 / 清洗 / scaling) | 证据:
[M]| 来源: IEEE Spectrum Robotics |2026-09-10 - 关键数字:
100 hours·12 tasks·3,000 hours·30,000 hours - 含量化指标 / 含闭环成功率 / 含真机实验 / 含延迟或控制频率
- 为什么重要: 数据来源与清洗管道是当前真正的护城河,决定单位新任务的成本。
Dexterous manipulation remains one of the biggest barriers keeping robots from successfully tackling a wide range of everyday tasks.
2. Video Friday: Two Birotors Make a Quadrotor
- 主线: 仿真与评测(sim2real / 闭环) | 证据:
[M]| 来源: IEEE Spectrum Robotics |2026-09-18 - 关键数字:
33%·2x - 含闭环成功率 / 含延迟或控制频率
- 为什么重要: 评测方式决定你敢不敢上线:离线指标不等于闭环成功率,评测预算结构正在从人力转向 GPU 小时。
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics.
3. Fine-Tuning π0 (Pi-Zero) for robotic manipulation on Amazon SageMaker HyperPod EKS
- 主线: 基座模型(VLA / WAM) | 证据:
[O]| 来源: AWS Physical AI Blog |2026-09-10 - 含真机实验
- 为什么重要: 基座模型层的变化会直接决定下游所有任务的起点:它影响你需要多少自有数据、能不能跨本体迁移。
Introduction This post demonstrates how to fine-tune π0 (Pi-Zero), a 3-billion parameter flow matching Vision-Language-Action model from Physical Intelligence, on robot manipulation datasets using Amazon SageMaker HyperPod with Amazon…
4. Digit 5 May Be the First Humanoid Robot Worker That’s Truly Safe
- 主线: 本体与供应链(硬件 / 成本) | 证据:
[M]| 来源: IEEE Spectrum Robotics |2026-09-15 - 关键数字:
20 hours - 含量化指标 / 含延迟或控制频率
- 为什么重要: 本体与供应链决定成本曲线和交付节奏,执行器仍是 BOM 的主要部分。
Despite the recent deluge of videos of humanoid robots doing backflips and kung fu, the actual pace of progress towards humanoids that can do economically viable jobs at scale has at times seemed a bit plodding.
5. Video Friday: Meet Microduck
- 主线: 本体与供应链(硬件 / 成本) | 证据:
[M]| 来源: IEEE Spectrum Robotics |2026-08-28 - 含量化指标 / 含真机实验 / 有开放代码或权重 / 含延迟或控制频率
- 为什么重要: 本体与供应链决定成本曲线和交付节奏,执行器仍是 BOM 的主要部分。
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics.
6. Video Friday: Digit Redecorates
- 主线: 仿真与评测(sim2real / 闭环) | 证据:
[M]| 来源: IEEE Spectrum Robotics |2026-09-04 - 含真机实验 / 有开放代码或权重
- 为什么重要: 评测方式决定你敢不敢上线:离线指标不等于闭环成功率,评测预算结构正在从人力转向 GPU 小时。
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics.
7. NVIDIA Vera Rubin NVL72 Delivers Leading Performance in MLPerf Inference v6.1 Debut
- 主线: 边缘与实时性(端侧推理 / 控制频率) | 证据:
[O]| 来源: NVIDIA Blog |2026-09-16 - 含延迟或控制频率
- 为什么重要: 端侧延迟与控制频率是硬约束:模型再强,超出实时预算就不能进入控制回路。
System performance, efficient infrastructure scaling and continuous software optimization are key levers that determine AI inference economics.
8. Cute Critters Come to the Cloud: ‘Aniimo’ Launches on GeForce NOW
- 主线: 训练与自我改进(RL / 后训练) | 证据:
[O]| 来源: NVIDIA Blog |2026-09-17 - 为什么重要: 后训练与自我改进决定策略在部署后还能不能变强,也决定运维是否要收集干预数据。
A new creature-catching adventure is ready to stream from the cloud this week. Pawprint Studio’s Aniimo arrives on GeForce NOW at launch, inviting gamers to explore the vibrant continent of Idyll across supported devices.
前沿基线(人工策展)
1. Post-train NVIDIA Cosmos 3 Edge for on-device robot control
- 主线: 边缘与实时性(端侧推理 / 控制频率) | 证据:
[O]| 来源: NVIDIA Technical Blog |2026-08 - 关键数字:
4B omni-model·2B Nemotron reasoner·runs on Jetson Thor·receding-horizon control loop - 含闭环成功率 / 有开放代码或权重
- 为什么重要: 世界模型进端侧的第一条可复现路径:post-train 到 Thor 上服务、再闭环评测,代码与 checkpoint 都公开。
2. Fine-tuning π0 for robotic manipulation on Amazon SageMaker HyperPod EKS
- 主线: 训练与自我改进(RL / 后训练) | 证据:
[O]| 来源: AWS Physical AI Blog |2026-09-10 - 关键数字:
MSE -89.7% (DROID)·MSE -88.9% (LIBERO)·8xH100, 20k steps, 6h15m·50-step chunk <200 ms at 1 ODE step·checkpoint ~45 GB - 为什么重要: 同一工作早期报 96% 改善,只因评测集与训练集重叠;修正切分后是 89%。这是 2026 年最值得引用的评测纪律案例。
3. EgoScale: scaling dexterous manipulation with diverse egocentric human data
- 主线: 数据引擎(采集 / 清洗 / scaling) | 证据:
[R]| 来源: arXiv 2602.16710 |2026 - 关键数字:
44k hours of egocentric video·+54% average success vs no-pretraining on a 22-DoF hand·transfers to lower-DoF hands - 为什么重要: 大规模人类动作被证明是可复用、跨本体的 motor prior,灵巧手不必从零学起。
4. PL-CBF: finite-horizon safety at runtime via parallel fallback rollouts
- 主线: 安全、权限与合规 | 证据:
[R]| 来源: arXiv 2605.16588 |2026 - 关键数字:
library of fallback policies·least-invasive safe mode·QP minimally modifies the nominal policy - 为什么重要: “最小侵入回退”可以直接写进客户验收标准,比”我们很安全”具体得多。
5. LeRobotDataset v3.0: a standardised, streamable format for robot learning data
- 主线: 数据引擎(采集 / 清洗 / scaling) | 证据:
[O]| 来源: Hugging Face |2026 - 关键数字:
Parquet + MP4 + relational metadata·multi-episode packing·native streaming for multi-TB datasets - 为什么重要: 格式之争正收敛为数据用 LeRobot v3、资产用 OpenUSD;能一键转换的数据,其资产价值远高于锁在私有格式里的同等小时数。
6. HumanEgo: zero-shot robot learning from minutes of human egocentric video
- 主线: 数据引擎(采集 / 清洗 / scaling) | 证据:
[R]| 来源: arXiv 2605.24934 |2026 - 关键数字:
30 min/task -> 92.5% average success on 4 real tasks·15 min -> 75%·+41% over matched-time teleoperation - 为什么重要: 把”单位新任务的数据成本”压到分钟级,这是判断数据策略是否落后的最直接基准。
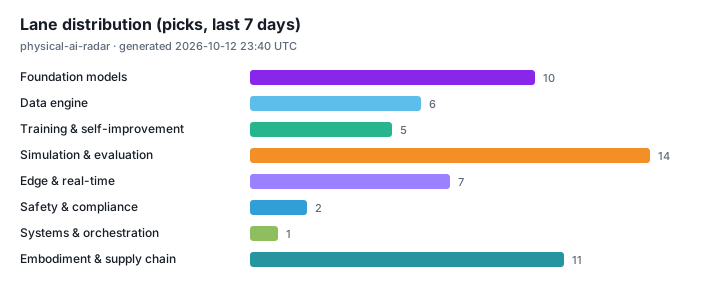
主线分布
| 主线 | # |
|---|---|
| 基座模型(VLA / WAM) | 4 |
| 数据引擎(采集 / 清洗 / scaling) | 6 |
| 训练与自我改进(RL / 后训练) | 5 |
| 仿真与评测(sim2real / 闭环) | 6 |
| 边缘与实时性(端侧推理 / 控制频率) | 6 |
| 安全、权限与合规 | 5 |
| 系统与编排(长程 / 多策略) | 1 |
| 本体与供应链(硬件 / 成本) | 4 |
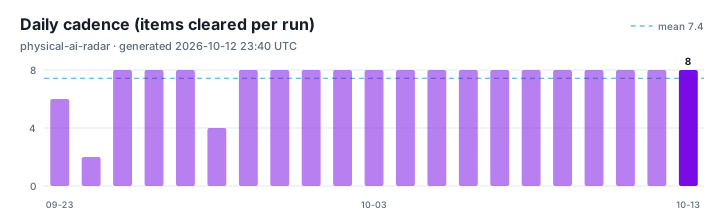
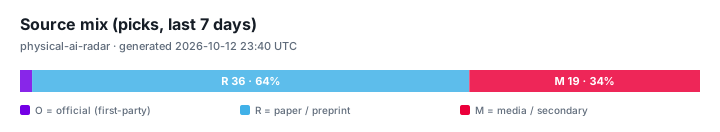
近期节奏
合规与标准观察
- ISO 25785-1 — Safety requirements for dynamically stable industrial mobile robots — Under development; committee-stage as of 2026-09.
- Regulation (EU) 2023/1230 (Machinery Regulation) — Fully applicable 2027-01-20.
- EU AI Act official timeline (Council of the EU) — High-risk deadlines 2027-12-02 / 2028-08-02 per Digital Omnibus.
本仓库为技术观察,不构成投资建议、产品承诺或安全认证结论。论文结论以作者自报为准。