Physical AI フロンティア・レーダー · 2026-09-20
フィジカルAIの最前線を毎日更新:8つの軸、三言語の要約、追跡可能な根拠。
- 生成時刻:
2026-09-20 01:51 UTC - 対象期間:
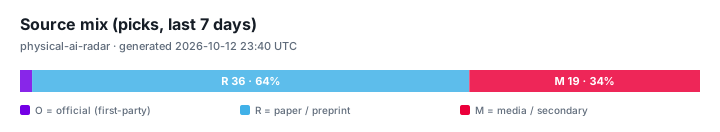
2026-09-17 → 2026-09-20 (UTC) - 根拠タグ:O = 一次情報 · R = 論文/プレプリント · M = メディア/二次情報
本日の注目
1. Robots Are Learning to Feel
- 軸: データエンジン(収集 / 精査 / スケーリング) | 根拠:
[M]| 出典: IEEE Spectrum Robotics |2026-09-10 - 主要数値:
100 hours·12 tasks·3,000 hours·30,000 hours - 定量結果あり / 閉ループ成功率あり / 実機実験あり / 遅延・制御周期の数値あり
- 重要な理由: データの取得元と精査パイプラインが現在の真の堀であり、新規タスク単価を決める。
Dexterous manipulation remains one of the biggest barriers keeping robots from successfully tackling a wide range of everyday tasks.
2. Video Friday: Two Birotors Make a Quadrotor
- 軸: シミュレーションと評価(sim2real / 閉ループ) | 根拠:
[M]| 出典: IEEE Spectrum Robotics |2026-09-18 - 主要数値:
33%·2x - 閉ループ成功率あり / 遅延・制御周期の数値あり
- 重要な理由: 評価手法が出荷判断を決める:オフライン指標は閉ループ成功率ではなく、評価予算は人手からGPU時間へ移りつつある。
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics.
3. Fine-Tuning π0 (Pi-Zero) for robotic manipulation on Amazon SageMaker HyperPod EKS
- 軸: 基盤モデル(VLA / WAM) | 根拠:
[O]| 出典: AWS Physical AI Blog |2026-09-10 - 実機実験あり
- 重要な理由: 基盤モデル層の変化は下流タスクの出発点を変える:自社データの必要量と、機体間で転移できるかを左右する。
Introduction This post demonstrates how to fine-tune π0 (Pi-Zero), a 3-billion parameter flow matching Vision-Language-Action model from Physical Intelligence, on robot manipulation datasets using Amazon SageMaker HyperPod with Amazon…
4. Digit 5 May Be the First Humanoid Robot Worker That’s Truly Safe
- 軸: ハードウェアとサプライチェーン(機体 / コスト) | 根拠:
[M]| 出典: IEEE Spectrum Robotics |2026-09-15 - 主要数値:
20 hours - 定量結果あり / 遅延・制御周期の数値あり
- 重要な理由: 機体とサプライチェーンがコスト曲線と納入ペースを決め、アクチュエータがBOMの主要部分を占める。
Despite the recent deluge of videos of humanoid robots doing backflips and kung fu, the actual pace of progress towards humanoids that can do economically viable jobs at scale has at times seemed a bit plodding.
5. Video Friday: Meet Microduck
- 軸: ハードウェアとサプライチェーン(機体 / コスト) | 根拠:
[M]| 出典: IEEE Spectrum Robotics |2026-08-28 - 定量結果あり / 実機実験あり / コードまたは重み公開 / 遅延・制御周期の数値あり
- 重要な理由: 機体とサプライチェーンがコスト曲線と納入ペースを決め、アクチュエータがBOMの主要部分を占める。
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics.
6. Video Friday: Digit Redecorates
- 軸: シミュレーションと評価(sim2real / 閉ループ) | 根拠:
[M]| 出典: IEEE Spectrum Robotics |2026-09-04 - 実機実験あり / コードまたは重み公開
- 重要な理由: 評価手法が出荷判断を決める:オフライン指標は閉ループ成功率ではなく、評価予算は人手からGPU時間へ移りつつある。
Video Friday is your weekly selection of awesome robotics videos, collected by your friends at IEEE Spectrum robotics.
7. NVIDIA Vera Rubin NVL72 Delivers Leading Performance in MLPerf Inference v6.1 Debut
- 軸: エッジとリアルタイム(オンデバイス推論 / 制御周期) | 根拠:
[O]| 出典: NVIDIA Blog |2026-09-16 - 遅延・制御周期の数値あり
- 重要な理由: オンデバイスの遅延と制御周期は硬い制約:実時間予算を超えるモデルは制御ループに入れない。
System performance, efficient infrastructure scaling and continuous software optimization are key levers that determine AI inference economics.
8. Cute Critters Come to the Cloud: ‘Aniimo’ Launches on GeForce NOW
- 軸: 学習と自己改善(RL / 事後学習) | 根拠:
[O]| 出典: NVIDIA Blog |2026-09-17 - 重要な理由: 事後学習と自己改善は、配備後も方策が強くなれるか、運用で介入データを取る必要があるかを決める。
A new creature-catching adventure is ready to stream from the cloud this week. Pawprint Studio’s Aniimo arrives on GeForce NOW at launch, inviting gamers to explore the vibrant continent of Idyll across supported devices.
フロンティア基準(キュレーション)
1. Post-train NVIDIA Cosmos 3 Edge for on-device robot control
- 軸: エッジとリアルタイム(オンデバイス推論 / 制御周期) | 根拠:
[O]| 出典: NVIDIA Technical Blog |2026-08 - 主要数値:
4B omni-model·2B Nemotron reasoner·runs on Jetson Thor·receding-horizon control loop - 閉ループ成功率あり / コードまたは重み公開
- 重要な理由: 世界モデルをオンデバイスで動かす最初の再現可能な道筋:事後学習してThorで提供し、閉ループで評価。コードと重みも公開。
2. Fine-tuning π0 for robotic manipulation on Amazon SageMaker HyperPod EKS
- 軸: 学習と自己改善(RL / 事後学習) | 根拠:
[O]| 出典: AWS Physical AI Blog |2026-09-10 - 主要数値:
MSE -89.7% (DROID)·MSE -88.9% (LIBERO)·8xH100, 20k steps, 6h15m·50-step chunk <200 ms at 1 ODE step·checkpoint ~45 GB - 重要な理由: 同じ作業の初期版は評価と学習のエピソードが重複し約96%と報告。分割を厳格化して約89%になった。2026年で最も引用価値のある評価規律の事例。
3. EgoScale: scaling dexterous manipulation with diverse egocentric human data
- 軸: データエンジン(収集 / 精査 / スケーリング) | 根拠:
[R]| 出典: arXiv 2602.16710 |2026 - 主要数値:
44k hours of egocentric video·+54% average success vs no-pretraining on a 22-DoF hand·transfers to lower-DoF hands - 重要な理由: 大規模な人間の動作が再利用可能で機体非依存のモータープライアであると示され、巧緻ハンドはゼロから学ばなくてよい。
4. PL-CBF: finite-horizon safety at runtime via parallel fallback rollouts
- 軸: 安全・権限・コンプライアンス | 根拠:
[R]| 出典: arXiv 2605.16588 |2026 - 主要数値:
library of fallback policies·least-invasive safe mode·QP minimally modifies the nominal policy - 重要な理由: 「最小侵襲のフォールバック」は顧客の受入基準にそのまま書ける。「安全です」より具体的。
5. LeRobotDataset v3.0: a standardised, streamable format for robot learning data
- 軸: データエンジン(収集 / 精査 / スケーリング) | 根拠:
[O]| 出典: Hugging Face |2026 - 主要数値:
Parquet + MP4 + relational metadata·multi-episode packing·native streaming for multi-TB datasets - 重要な理由: フォーマットはデータがLeRobot v3、アセットがOpenUSDへ収束。ワンステップで変換できるデータは、私有形式に閉じた同時間のデータより価値が高い。
6. HumanEgo: zero-shot robot learning from minutes of human egocentric video
- 軸: データエンジン(収集 / 精査 / スケーリング) | 根拠:
[R]| 出典: arXiv 2605.24934 |2026 - 主要数値:
30 min/task -> 92.5% average success on 4 real tasks·15 min -> 75%·+41% over matched-time teleoperation - 重要な理由: 新規タスクあたりのデータコストを分単位まで下げる。データ戦略の遅れを測る最も直接的な基準。
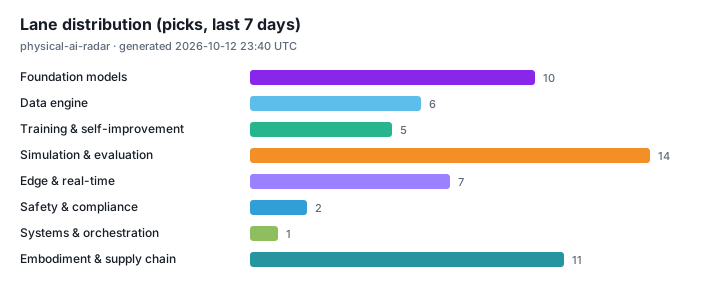
軸ごとの分布
| 軸 | # |
|---|---|
| 基盤モデル(VLA / WAM) | 4 |
| データエンジン(収集 / 精査 / スケーリング) | 6 |
| 学習と自己改善(RL / 事後学習) | 5 |
| シミュレーションと評価(sim2real / 閉ループ) | 6 |
| エッジとリアルタイム(オンデバイス推論 / 制御周期) | 6 |
| 安全・権限・コンプライアンス | 5 |
| システムとオーケストレーション(長期タスク / 複数方策) | 1 |
| ハードウェアとサプライチェーン(機体 / コスト) | 4 |
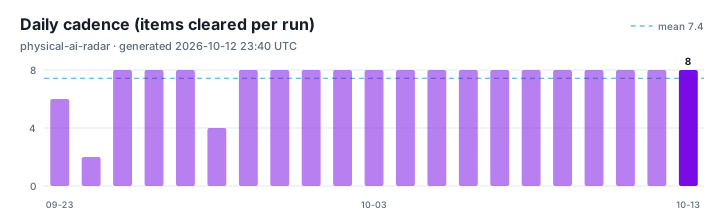
直近の推移
標準・規制ウォッチ
- ISO 25785-1 — Safety requirements for dynamically stable industrial mobile robots — Under development; committee-stage as of 2026-09.
- Regulation (EU) 2023/1230 (Machinery Regulation) — Fully applicable 2027-01-20.
- EU AI Act official timeline (Council of the EU) — High-risk deadlines 2027-12-02 / 2028-08-02 per Digital Omnibus.
本リポジトリは技術観察であり、投資助言・製品保証・安全認証の結論ではありません。論文の主張は著者による自己報告です。