Factory Twin Lab / campus × line × energy
Same shift. Same failure.
Close the loop.
A simulated plant streams noisy, lossy telemetry to its digital twin. The twin mirrors the line, estimates hidden spindle wear, forecasts the billed power demand, tests what-if plans on its own model and sends commands back. Replay the shift with the loop closed, or with the same twin in shadow mode, where it only advises.
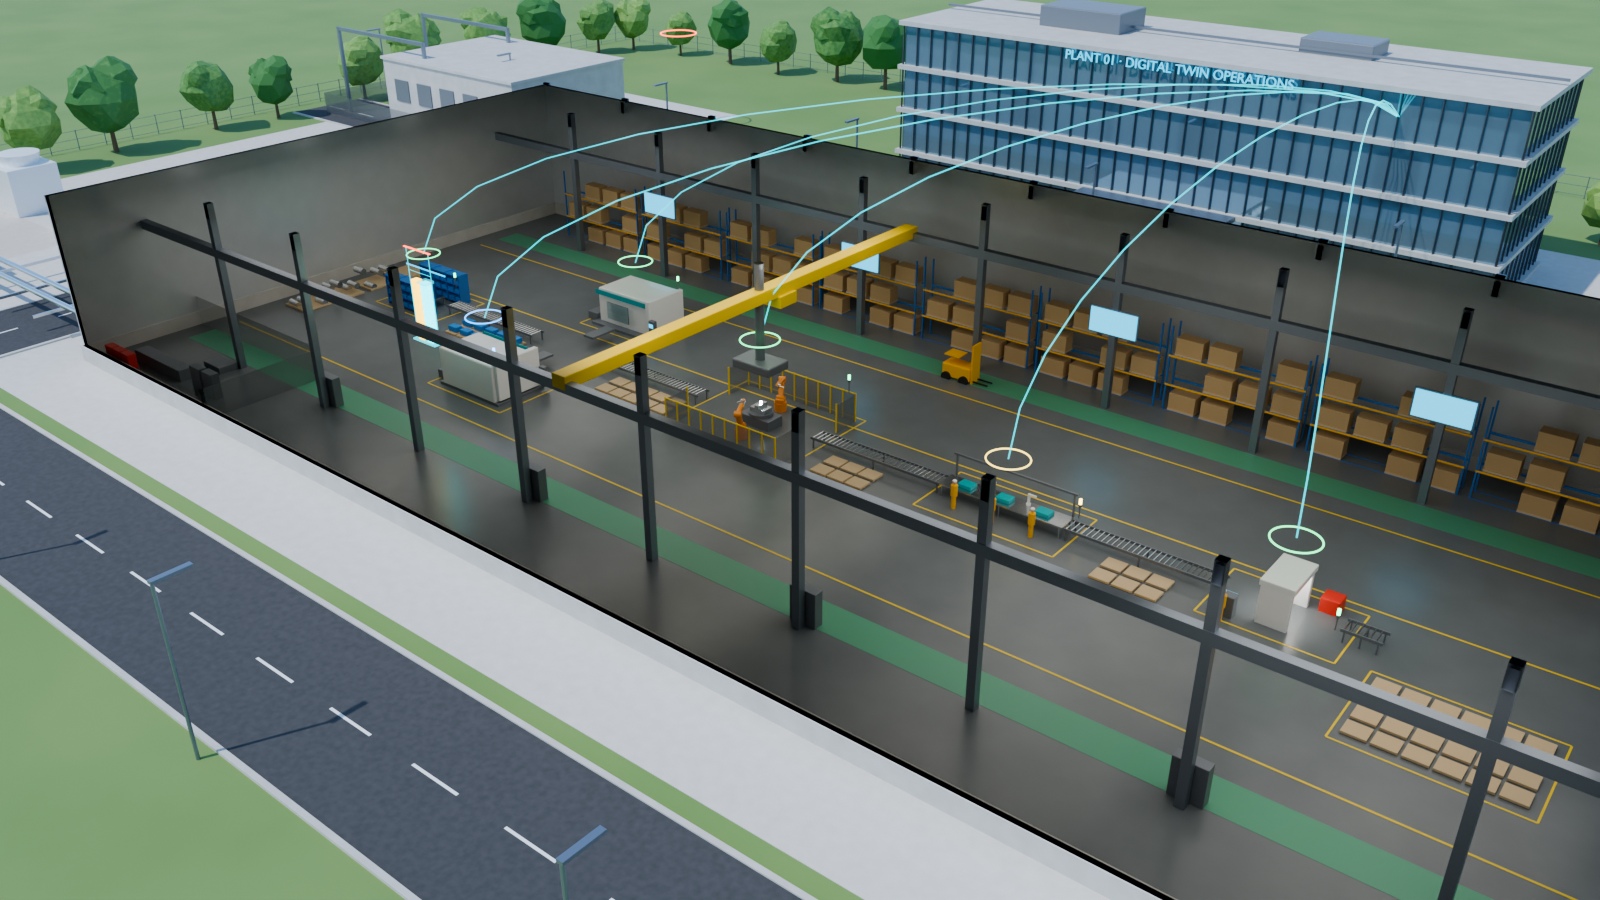
- PlantSix stations, 5 buffers, 3 AMRs, hall climate, PV, EV chargers. 1 s steps.
- TelemetryPLC, CNC, energy, hall and AMR packets every 5 s. 2–3% lost; one sample of latency.
- SyncThe twin mirrors buffers, states and AMR poses from the packets it actually received.
- EstimateExtended Kalman filter on vibration → CNC 2 wear and wear rate.
- PredictEvery 5 min: 14 what-if runs of its own line model over 90 min. 15-min demand forecast every minute.
- Decide & actService, feed derate, setpoint and EV caps. Applied after 5 s — or only logged.
Live campus, recorded shift
Loading the recorded shift…
CNC 2 wear: plant truth vs. the twin's estimate
Amber: true wear (hidden from the twin). Cyan: EKF estimate ±2σ. Red dotted: this plant's actual failure point; grey dashed: the twin's nominal threshold. Click to jump.
Good parts: closed loop vs. shadow
Same seed, same disturbances. The only difference is whether commands reach the plant.
Grid import and 15-minute billed demand
Line: instantaneous import. Bars: completed billing intervals. Red: demand limit.
Fly through the recorded shift
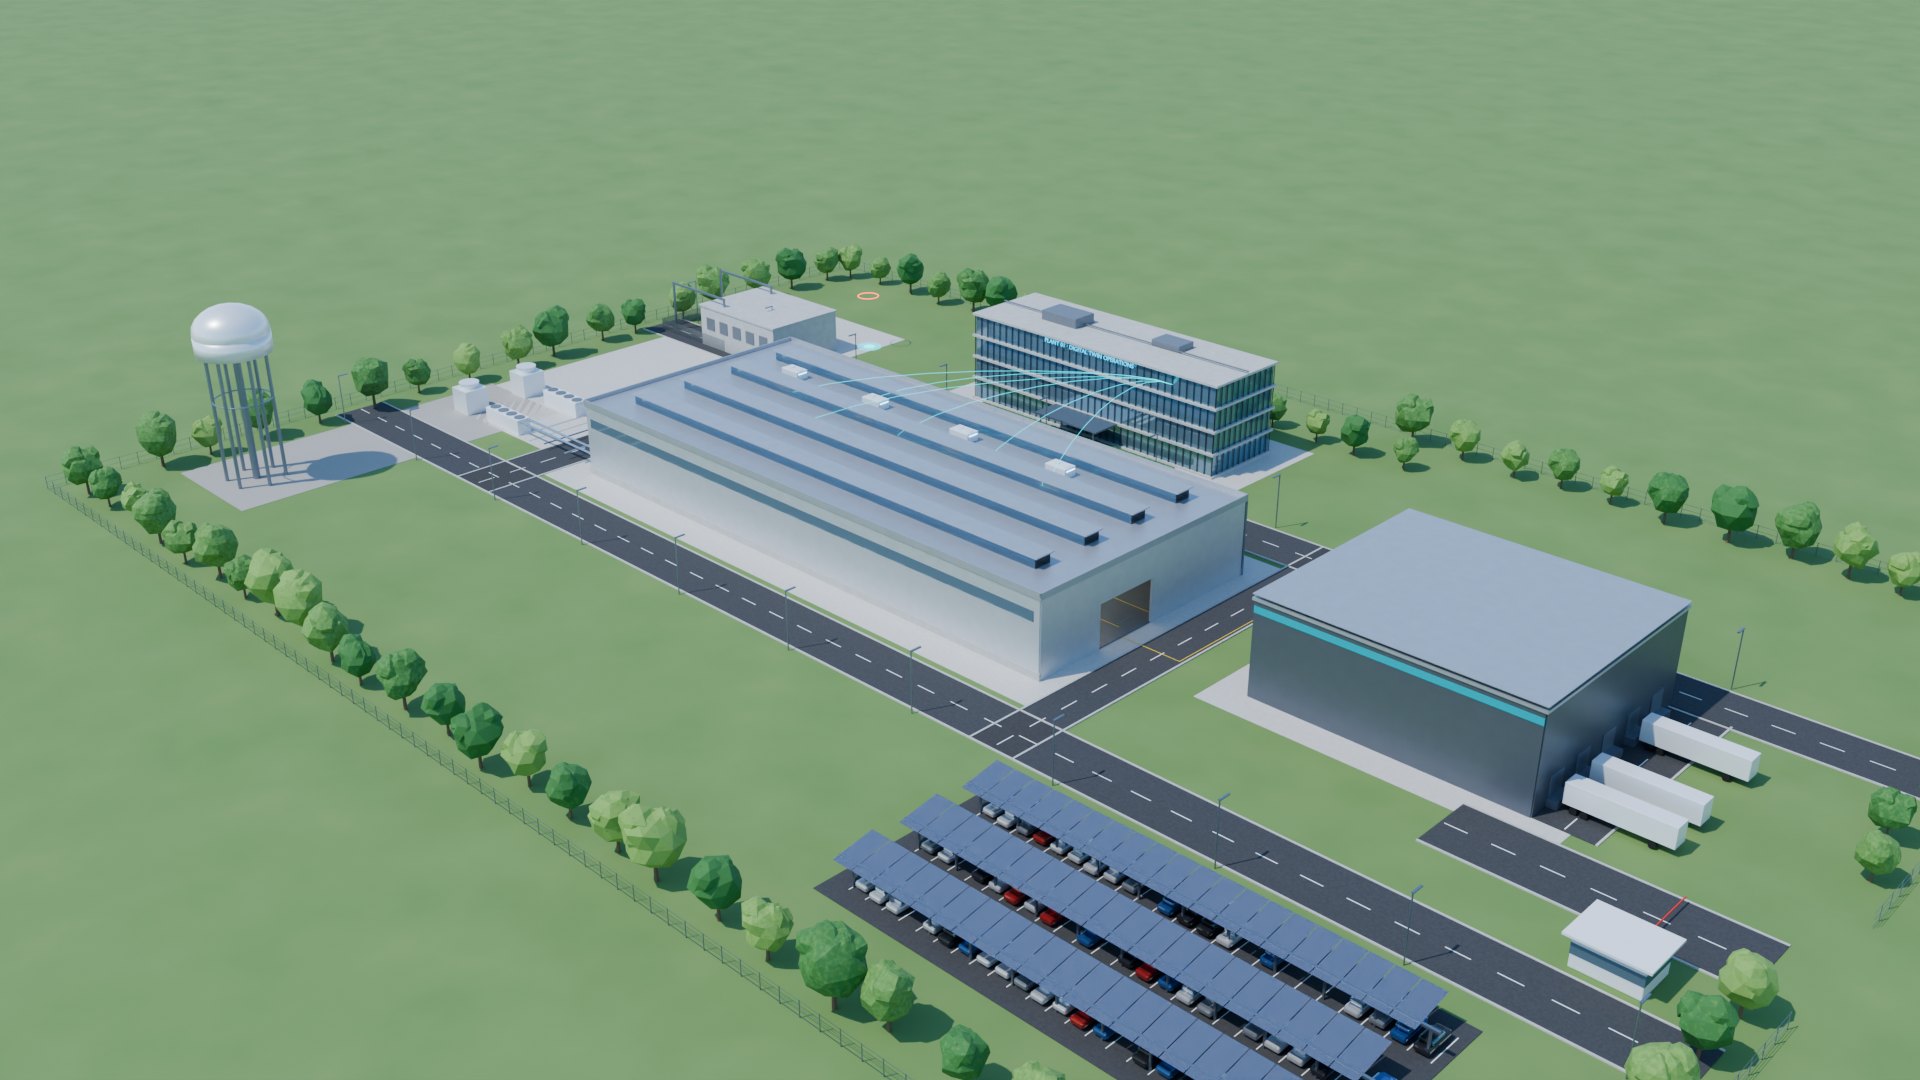
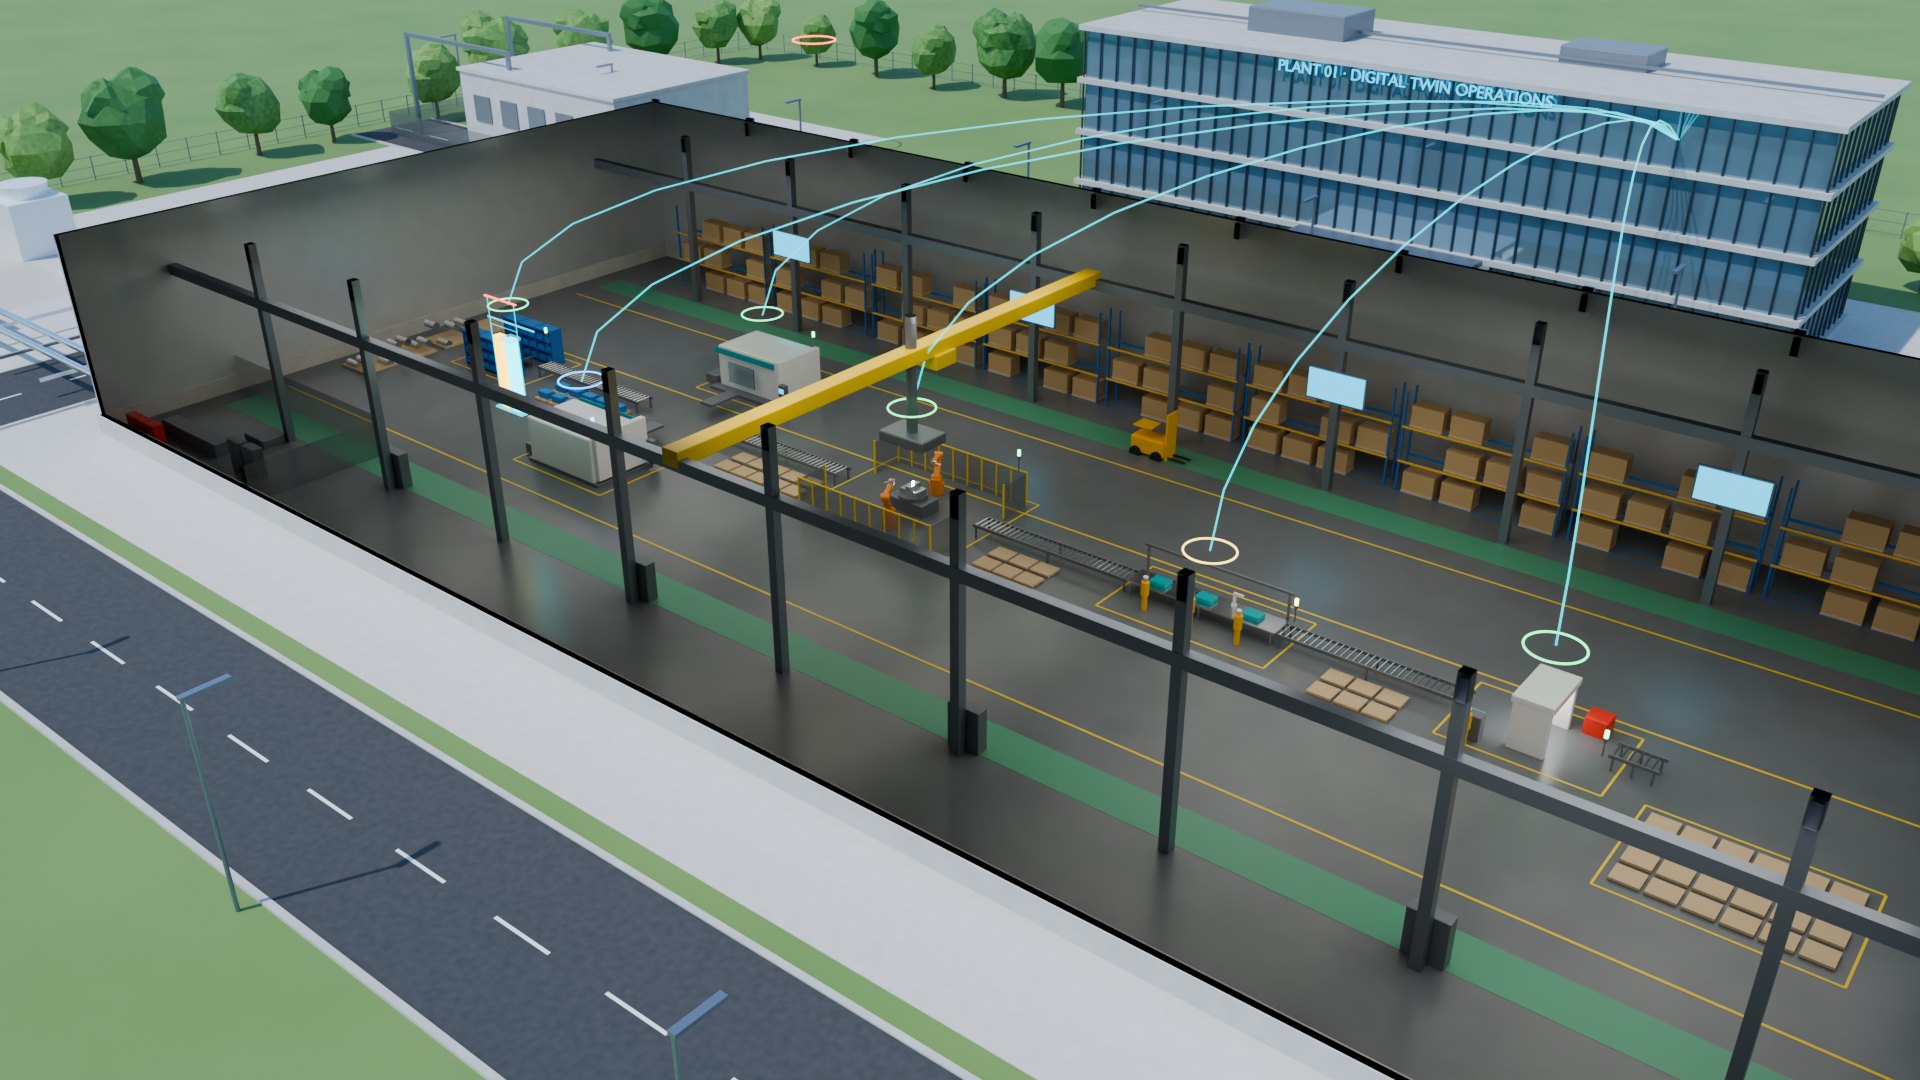
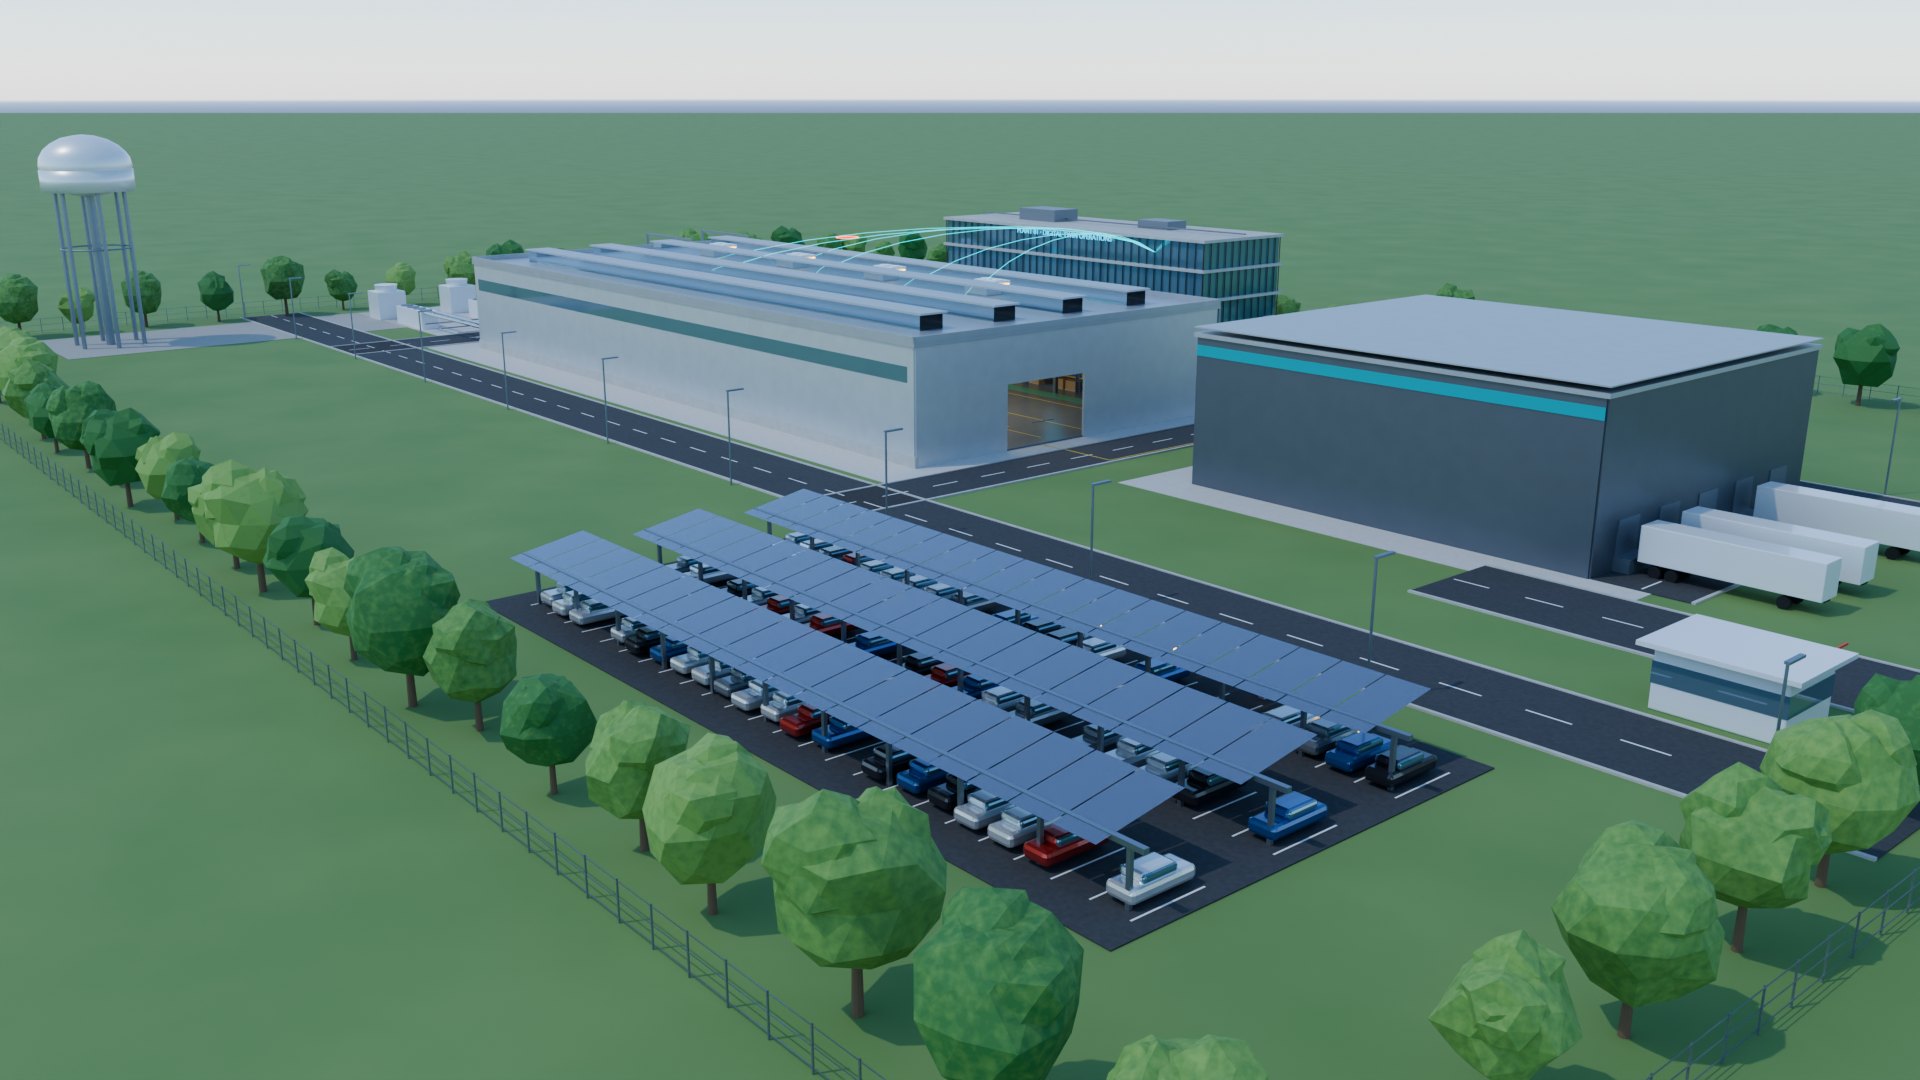
24 seconds of Cycles footage from the checked closed-loop Blender project. The camera path is cinematography; every frame shows one recorded sample, from 10:00 to 13:00, with the time map in film.json.
This copy does not include the film. Watch it on the project site ↗
Every decision, with its evidence.
| Time | Twin | Decision | Evidence → prediction | Jump |
|---|
Twelve paired shifts.
| Seed | Good parts shadow → closed | CNC 2 failures | Intervals over limit | Peak kW |
|---|
Everything here is simulated. The plant model, its parameters and the twin's cost weights were chosen for this demonstration; they are not calibrated to a real factory. The comparison shows what closing this loop changes inside this model, not the value of a digital twin in general.
Verify offline: robot-reel factory-twin --output factory-twin --verify re-executes the plant and twin with the standard library, replays the twin from the recorded telemetry alone and checks every file. Fingerprints · Blender & USD readback · Closed trace · Shadow trace